Nicholas Carr
Hardware background with software experience
I have been tinkering with technology for over 10 years. In that time, I have had broad exposure to many different technologies. From my work experience, attending dozens of hackathons, completing an undergrad in engineering physics, and building personal projects, I have had the opportunity to work with ESP32 microcontrollers, software-defined radio, 3D printers, React.js, and more.
Selected projects
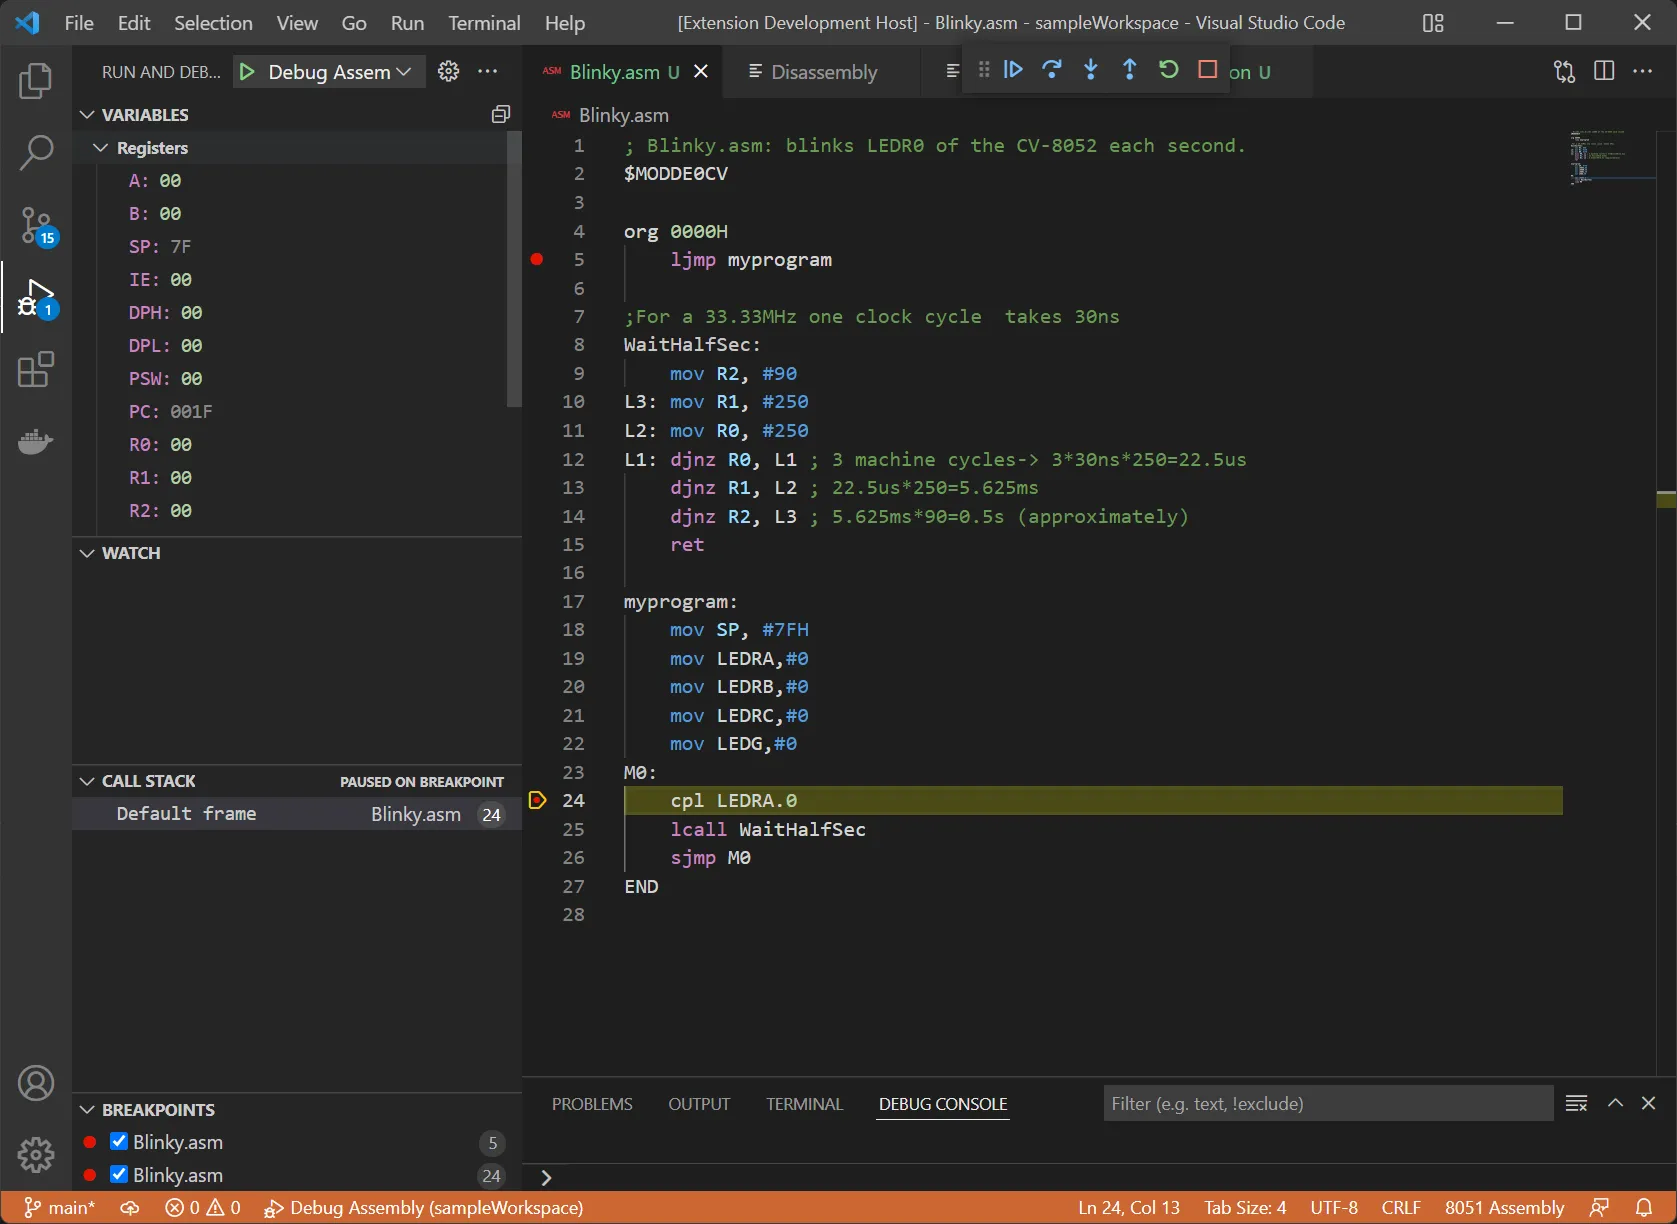
8051 Assembly Debug Adapter
Mar 2022 – Mar 2022
Adding VSCode debugging support to an assembly toolchain
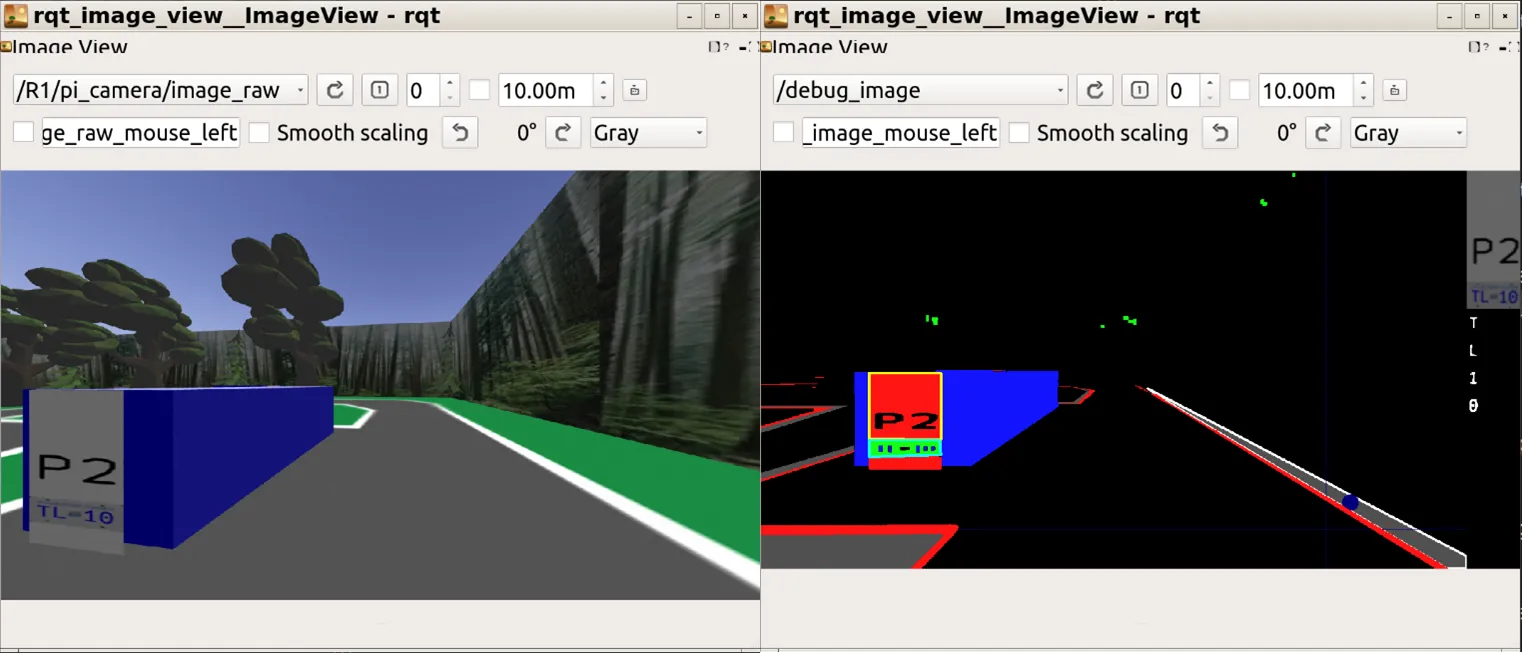
Autonomous Parking Enforcement Competition
Sep 2021 – Dec 2021
Autonomous robot controller to drive around a track reading license plates using ROS
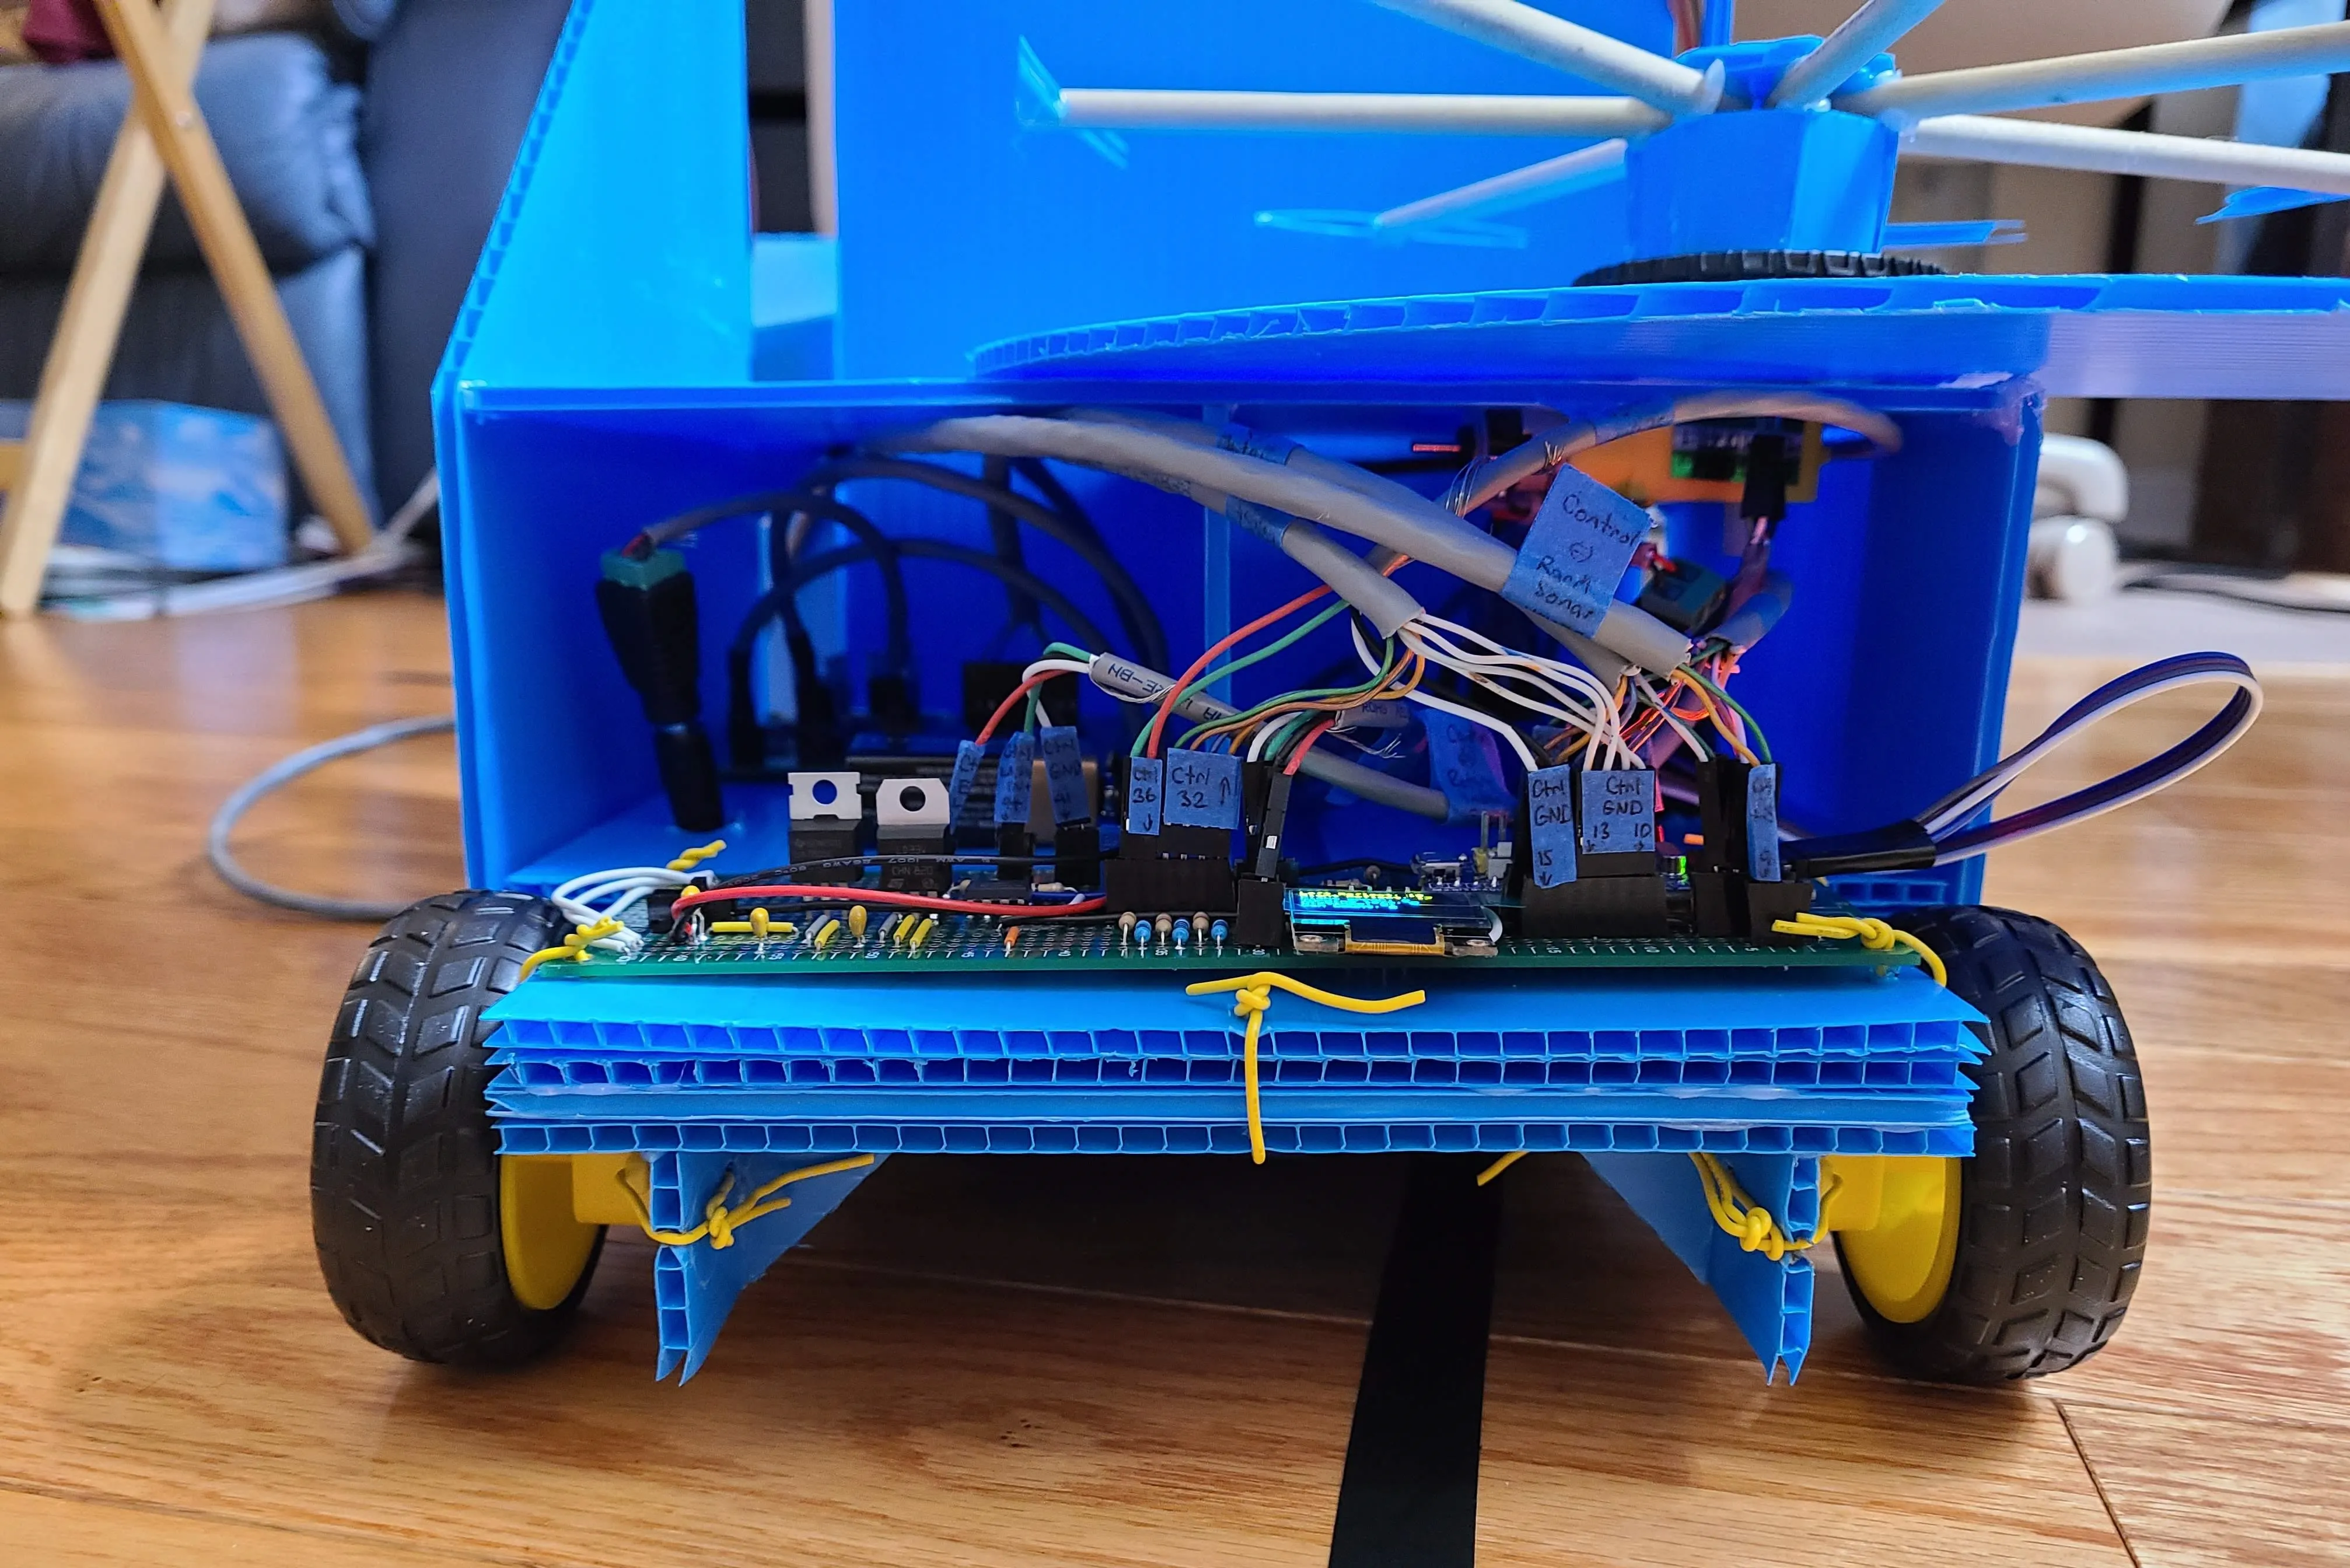
Autonomous Can Collecting Robot — The Revolver
May 2021 – Aug 2021
An autonomous rover created as part of a design course, hand-fabricated at home.
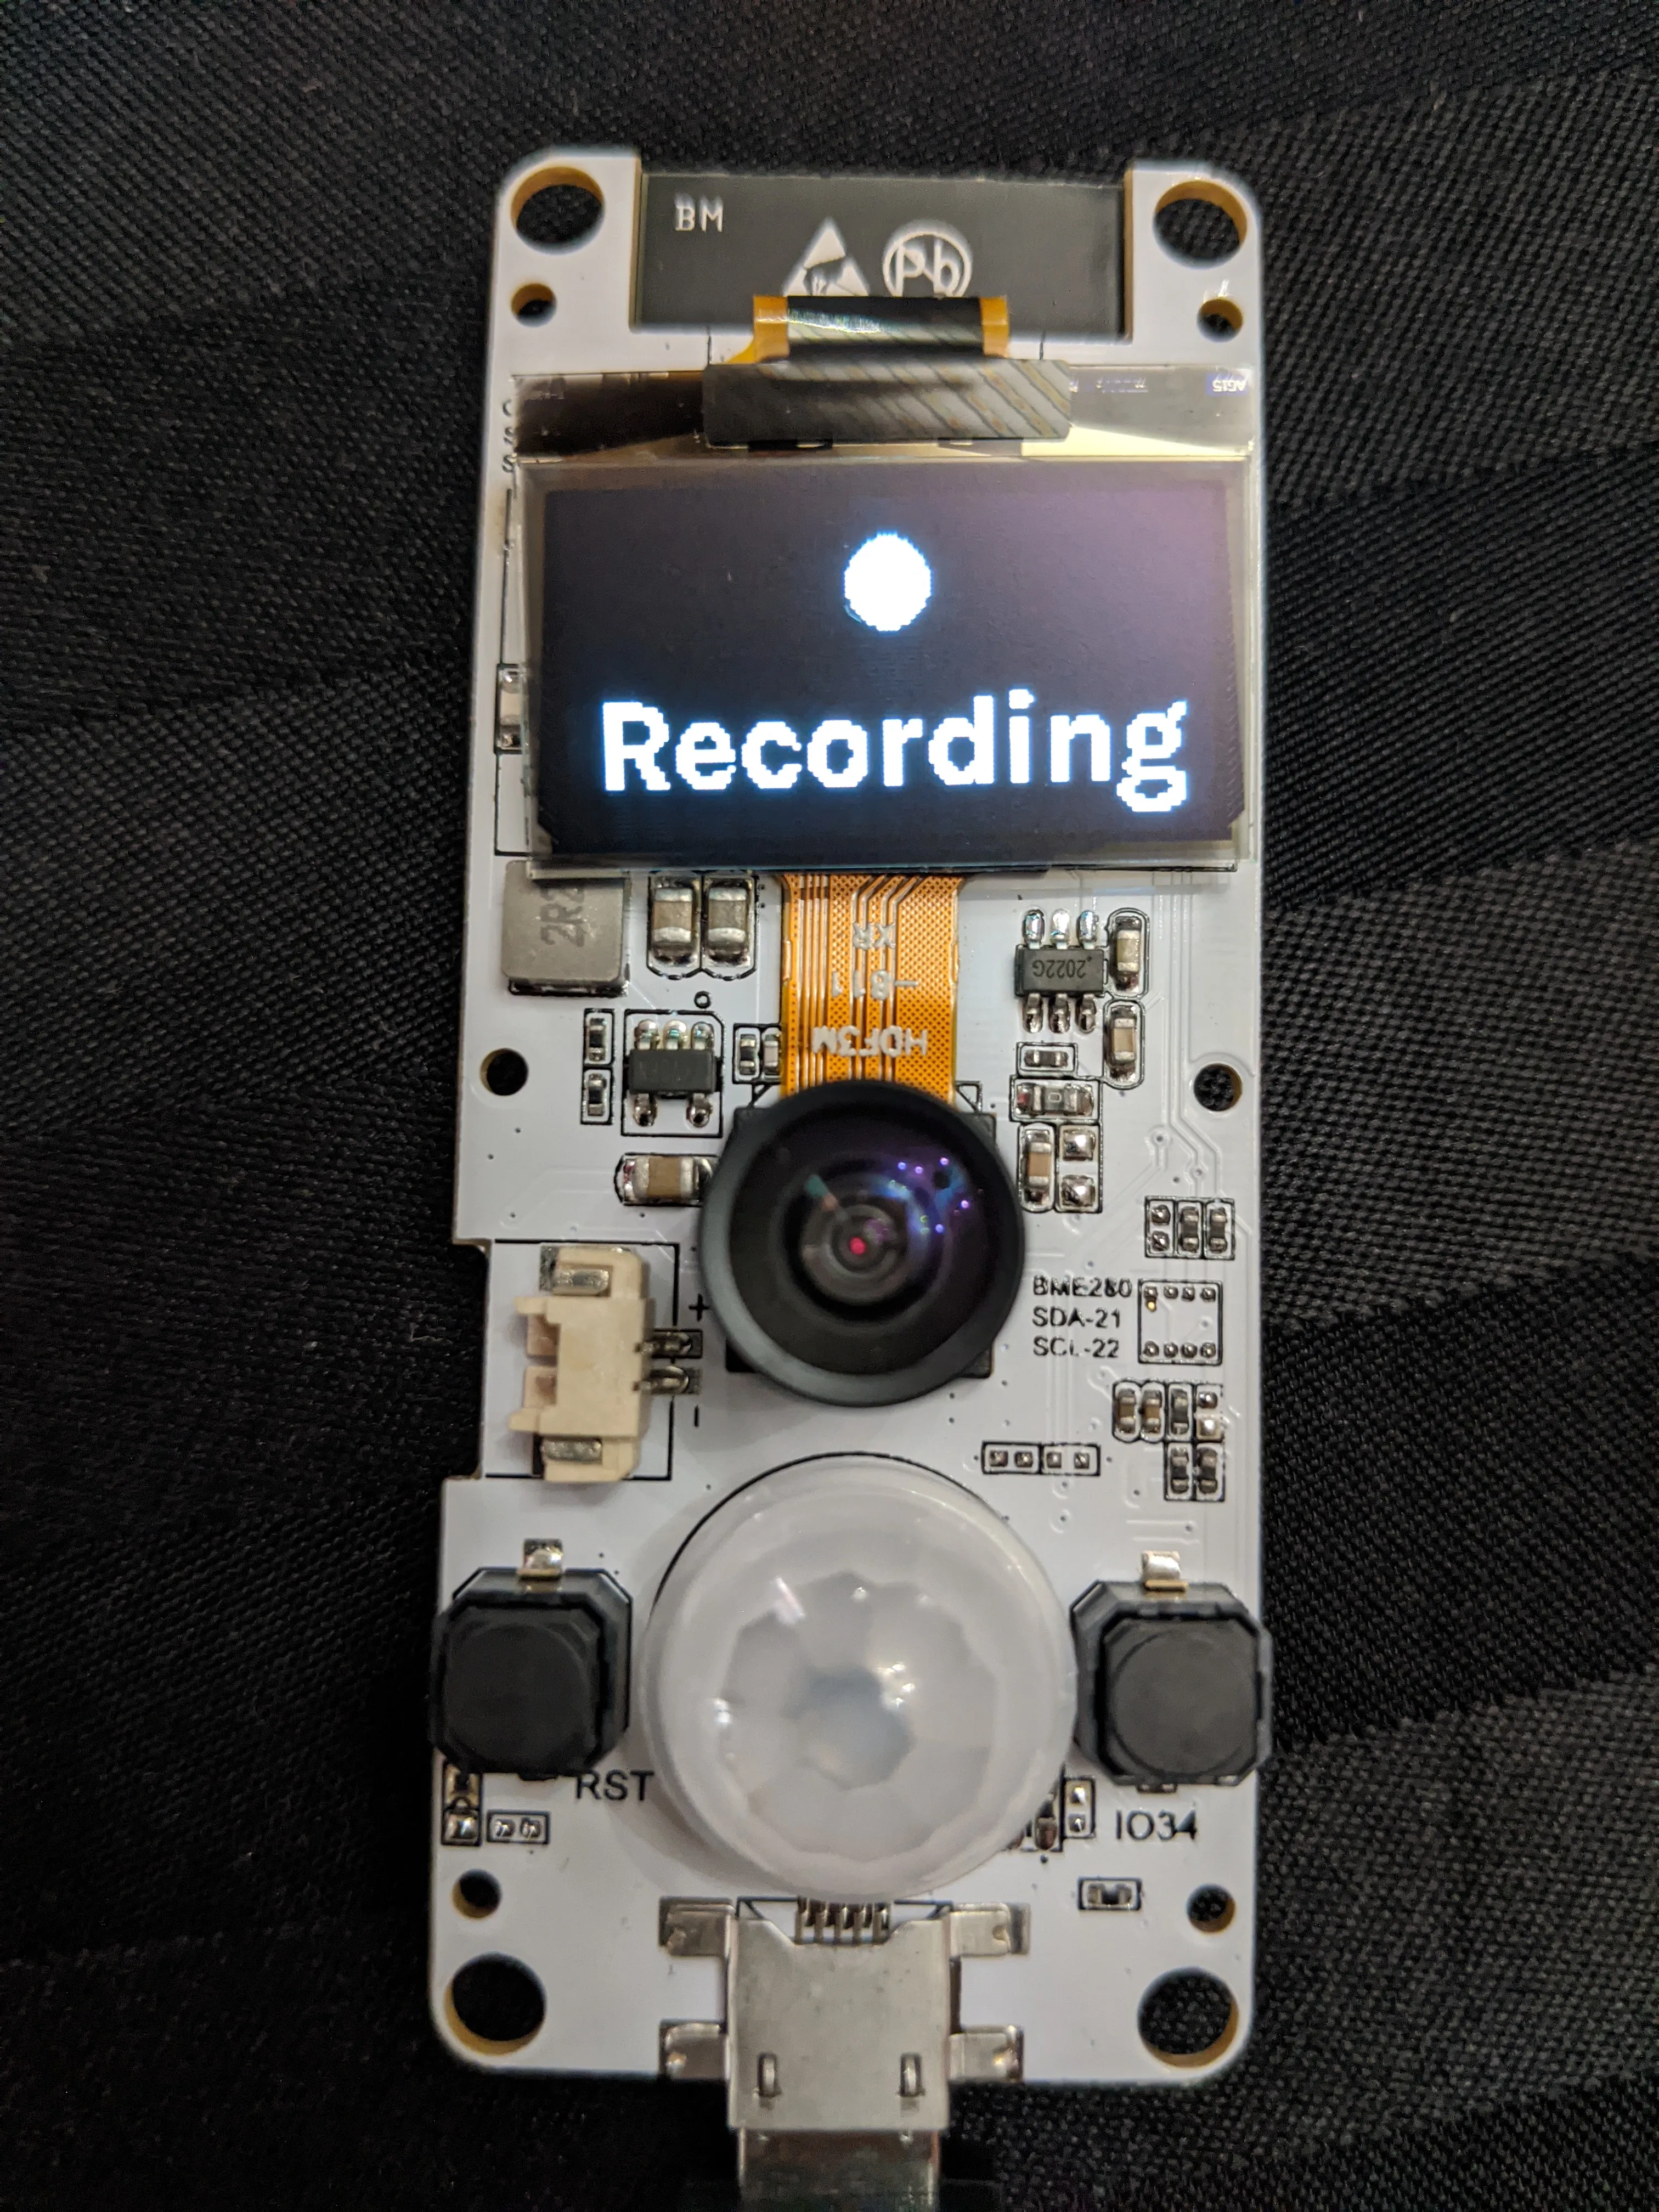
Video Doorbell Project
Aug 2020 – Aug 2020
Low-cost homemade video doorbell project
Work experience
Software Engineer
Alljoined
–
- Developed, tested, and integrated system for streaming brain signals to a compute cluster over the network using Python, NumPy, MNE, and LSL, enabling live inference on brain data
- Integrated Next.js-based internal scheduling webapp with Python experiment data management tool using FastAPI and Prisma, eliminating duplicate pre-session data entry
- Rebuilt alljoined.com to match new Figma design using Next.js and Tailwind CSS
- Owned web codebases and deployments, introduced a staging environment and database migrations to derisk updates, and Zod and TanStack Form to deduplicate validation logic
Steering Software Integration Intern
Tesla
–
- Wrote automated hardware-in-the-loop tests to validate CAN interfaces using pytest
- Updated factory calibration routines to support new ECU interfaces
- Created an automated tool to analyze aggregate data from the fleet using SQL queries
- Analyzed CAN signal traces using Vector CANape to verify correct operation between interconnected ECUs
Robotics Software Engineer Intern
Neupeak
–
- Built a web-based 3D visualization using THREE.js and live data from ROS to visualize the robot’s pose in real time, allowing operators to see the state of the robot remotely
- Implemented a 3D viewer to review previous point clouds and robot actions, allowing developers to debug reported errors from the field in depth
Control Systems Intern
Bioform
–
- Designed and wired sensor circuits for industrial control systems, allowing signals to be read by a controller and data acquisition system
- Specified and ordered wiring using component datasheets and application requirements
- Configured and tuned PID control for R&D production facility
- Wrote an application using Python and Qt to collect experiment data and control the facility
- Processed and generated plots for data combined from dozens of experiments using MATLAB
Education
Engineering Physics — Bachelor of Applied Science
UBC
Sep 2019 – May 2024
- Course selection included numerical methods, automatic control, signals and systems, software construction, machine design, quantum mechanics, and differential equations
Recent writing
Recent blog posts will appear here.
Browse the blog